Tianyi Zhang | 张天仪
Ph.D.
Hi! I'm Tianyi , a software engineer at Aurora, where I work on data-driven sensor simulation, turning real-world drive data into photorealistic, re-renderable scenes.
Before Aurora, I did my Ph.D. in Robotics at CMU, advised by Prof. Matthew Johnson-Roberson, working on 3D computer vision for robots: physics-based reconstruction, diffusion models, simulation, and 3D foundation models.
NEWS & Media Coverage: Our work featured by NOAA.gov (2023);
The LINK (Spring 2024);
CMU News (May 2024);
CMU News (Nov 2024);
Research
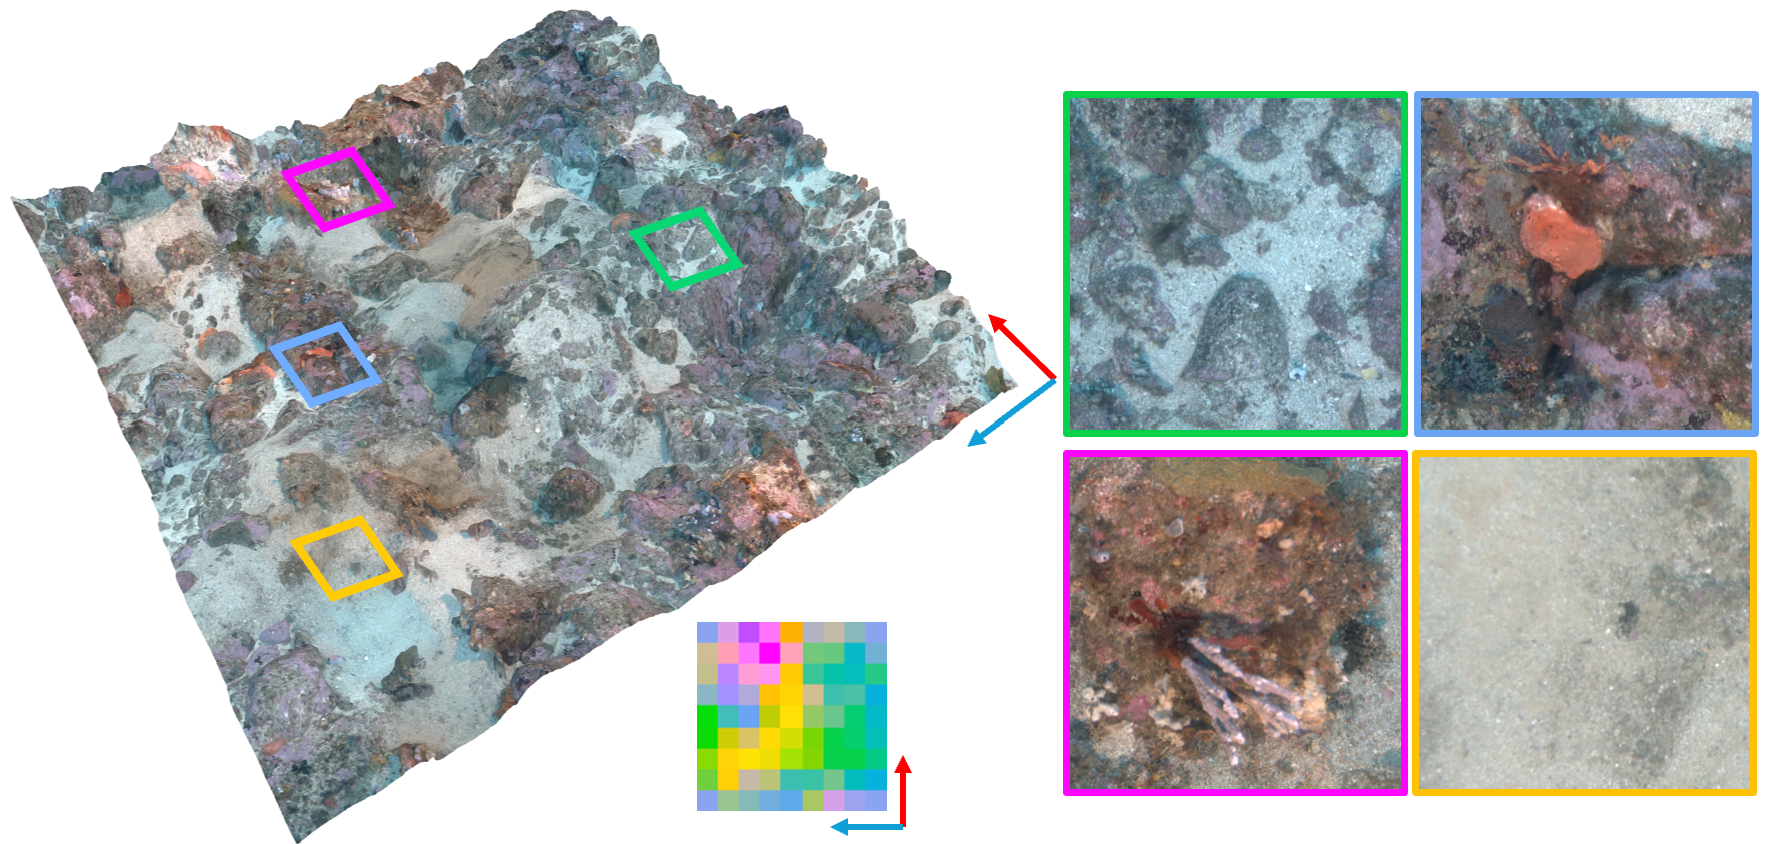
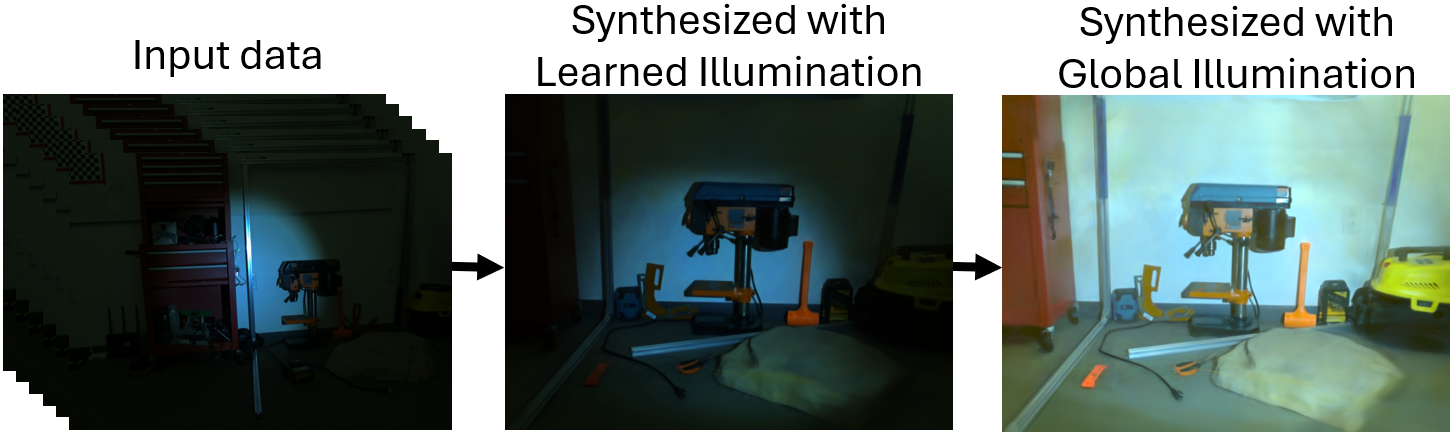
More Research & Projects (19)
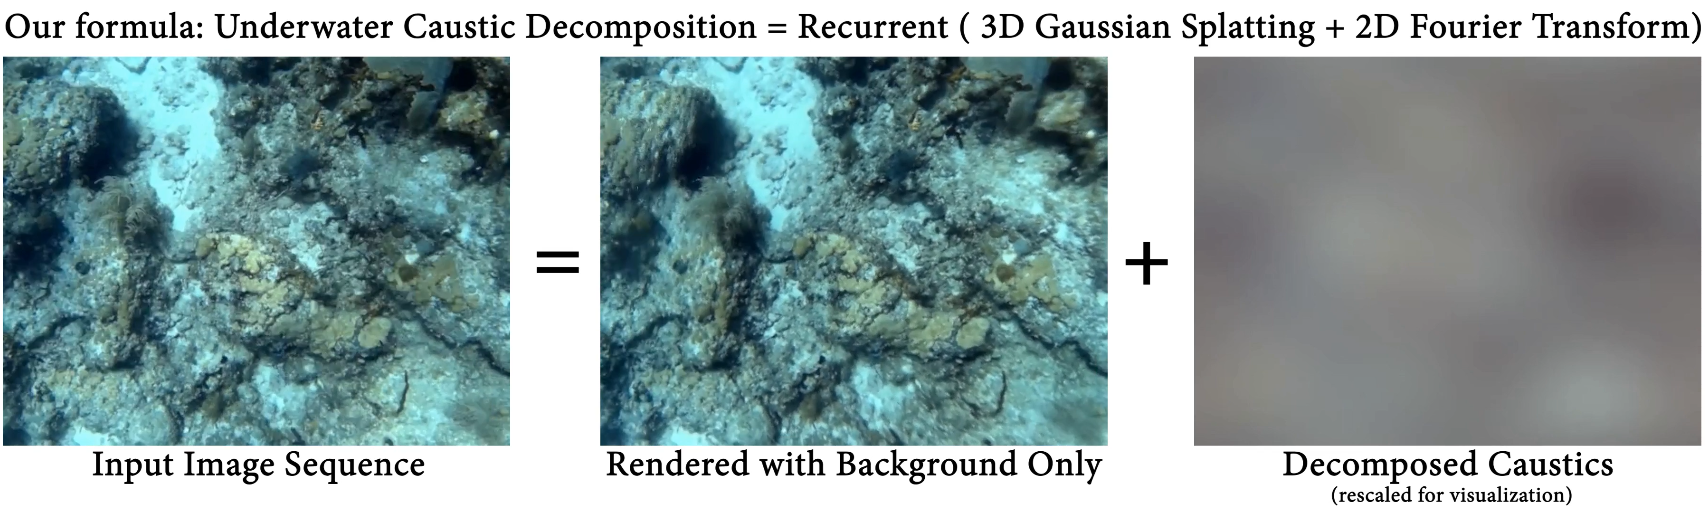
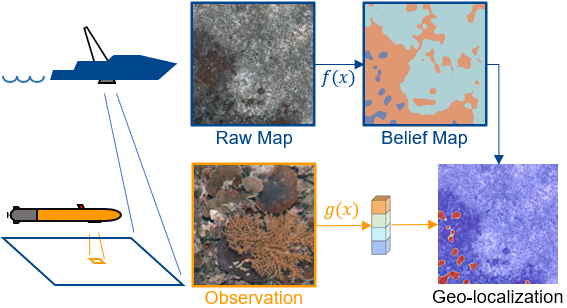
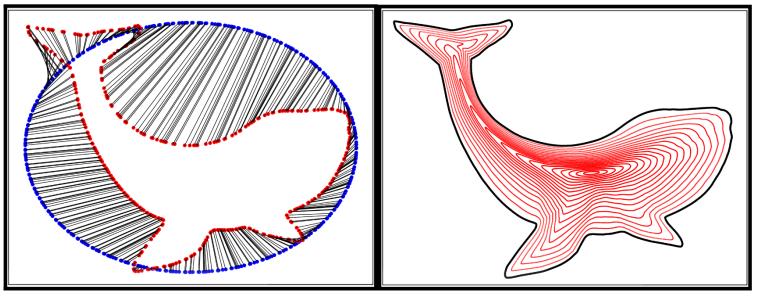
Learning Cross-Scale Visual Representations for Real-Time Image Geo-Localization
RA-L 2022, ICRA 2022
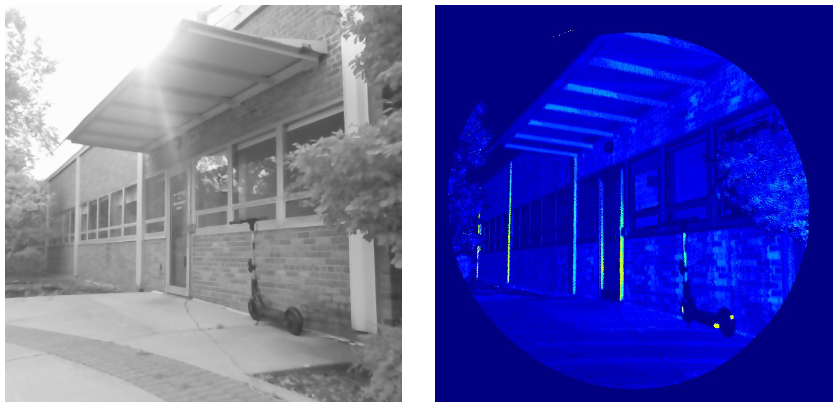
Features in the Point Cloud: An Automatic Approach to High Density LiDAR to Camera Calibration
Research report for M.S. Robotics degree, University of Michigan
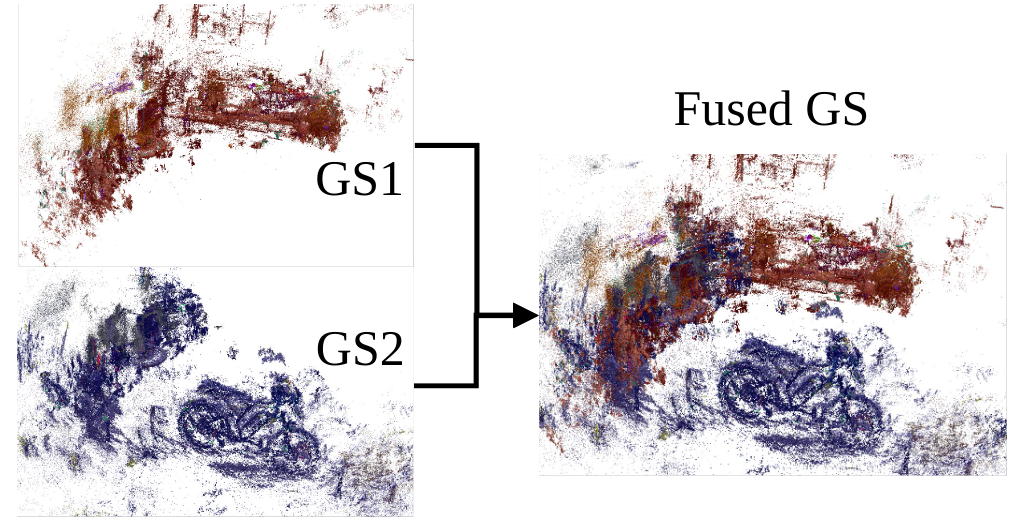
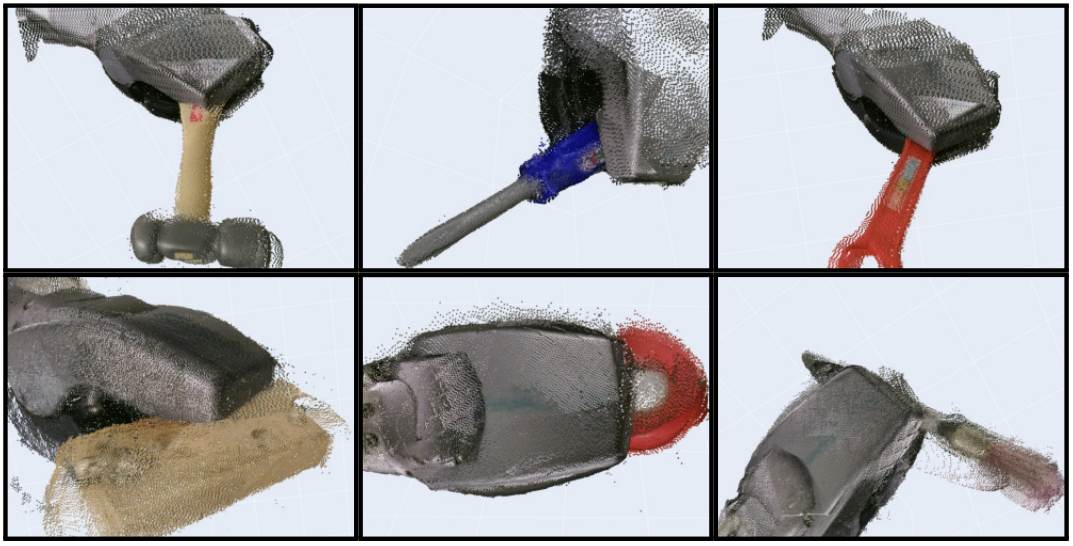
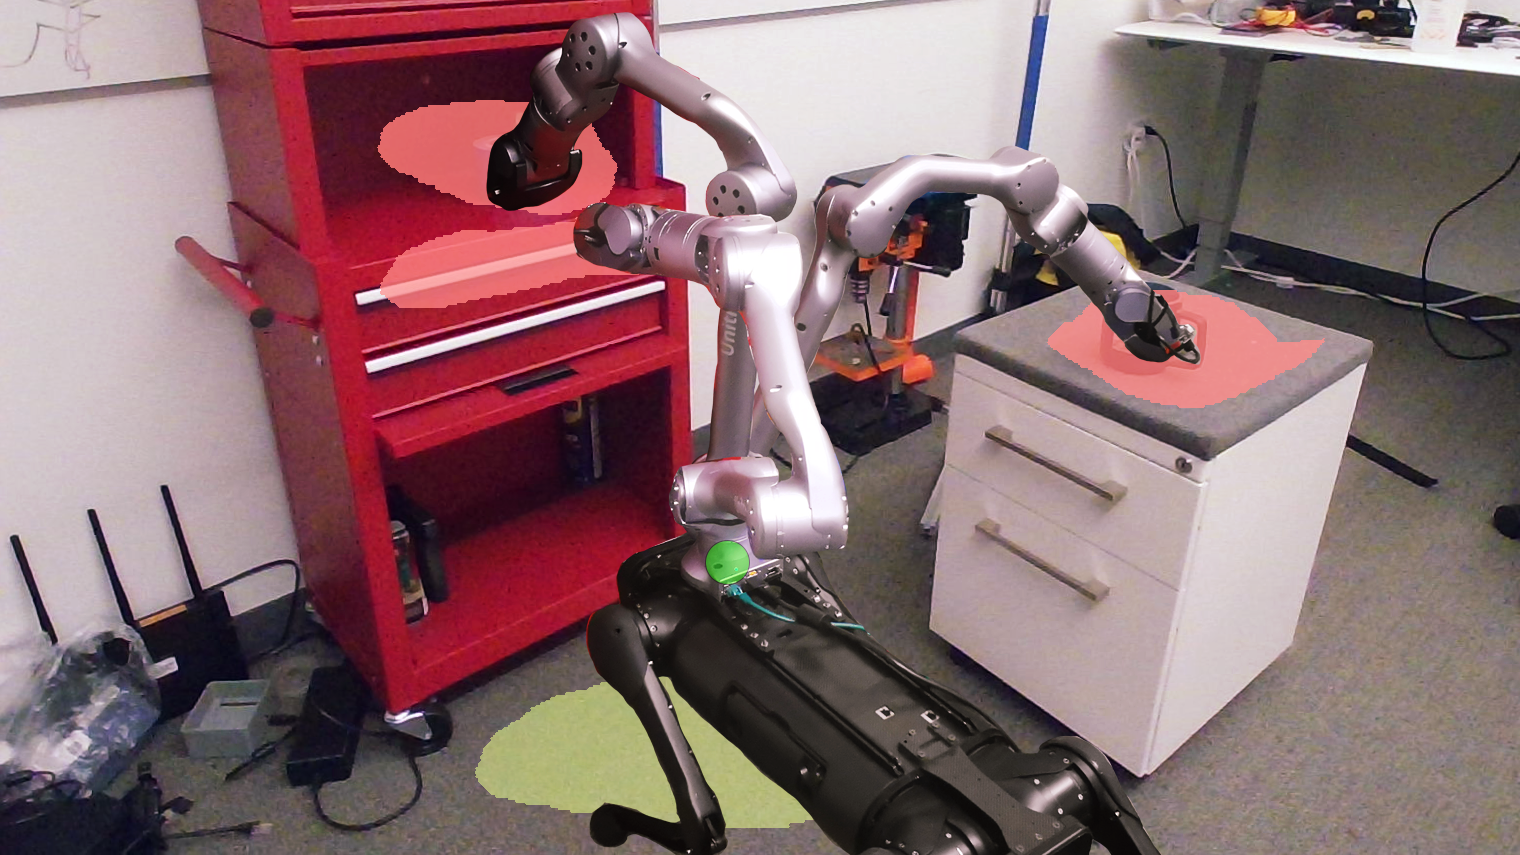
Simultaneous Geometry and Pose Estimation of Held Objects via 3D Foundation Models
RA-L 2024, ICRA 2025
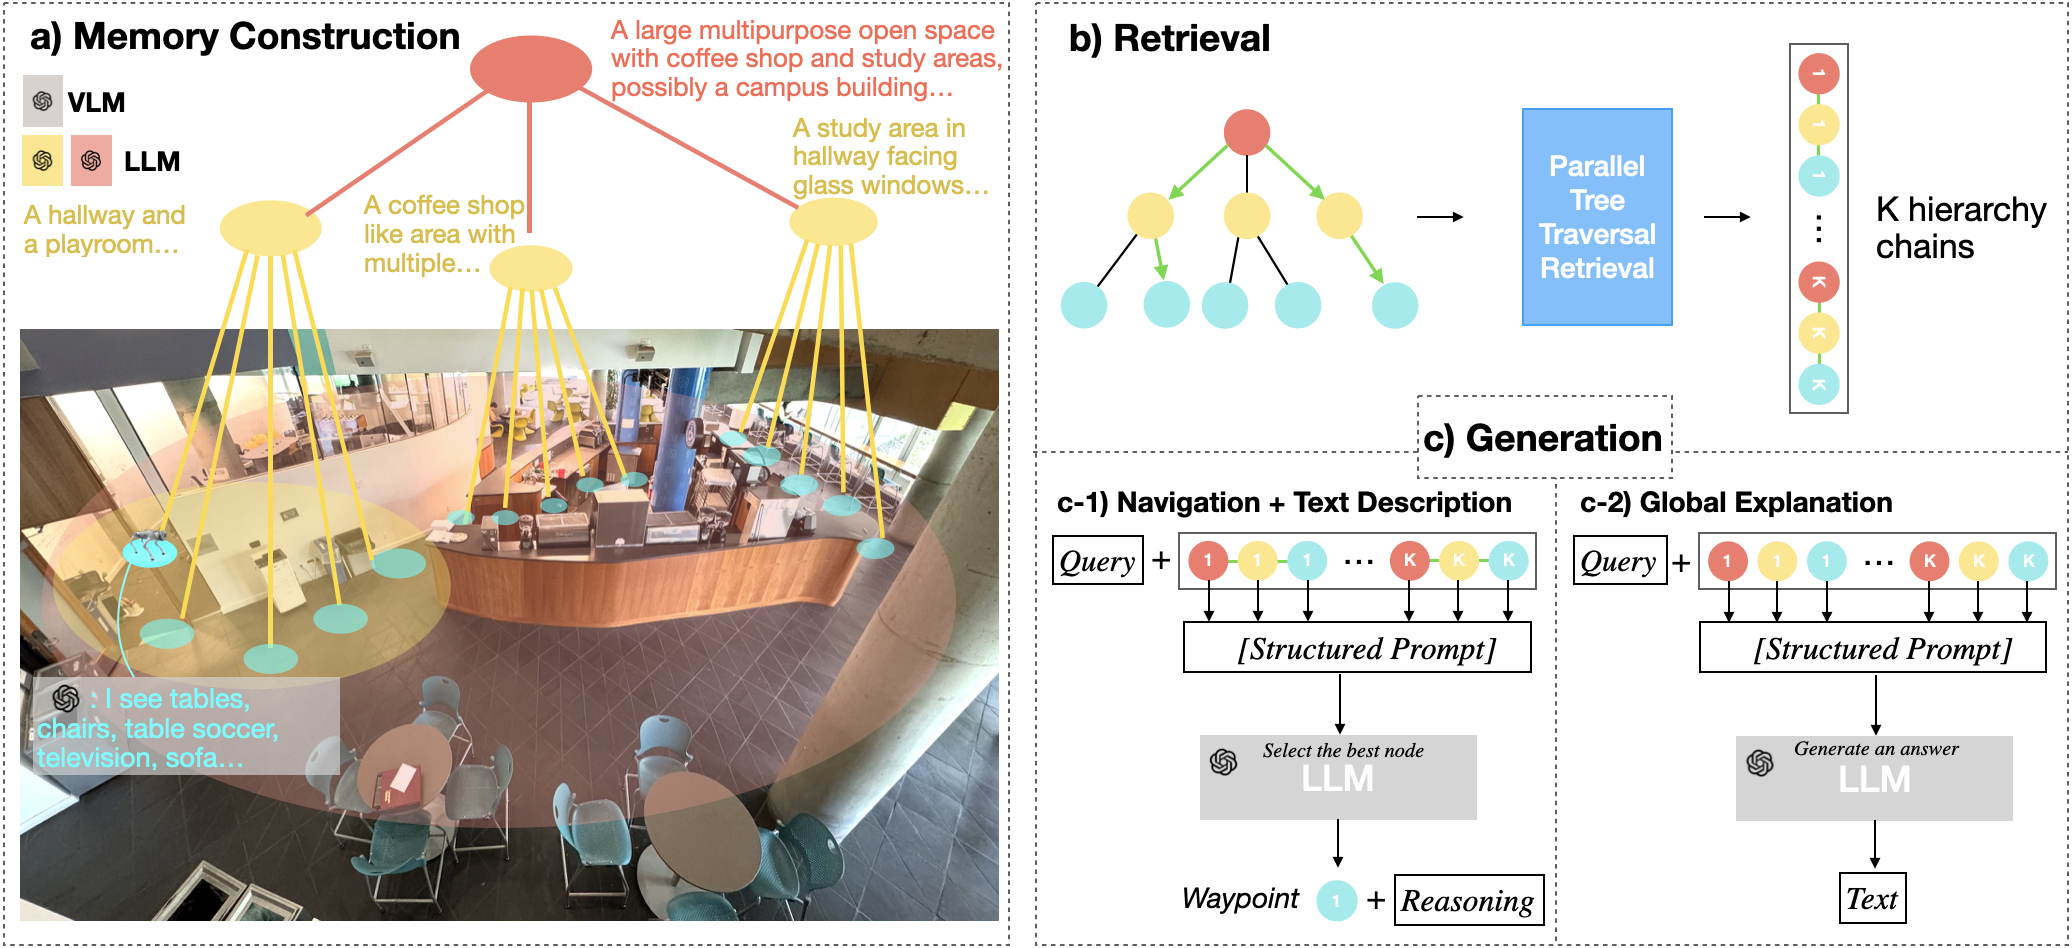
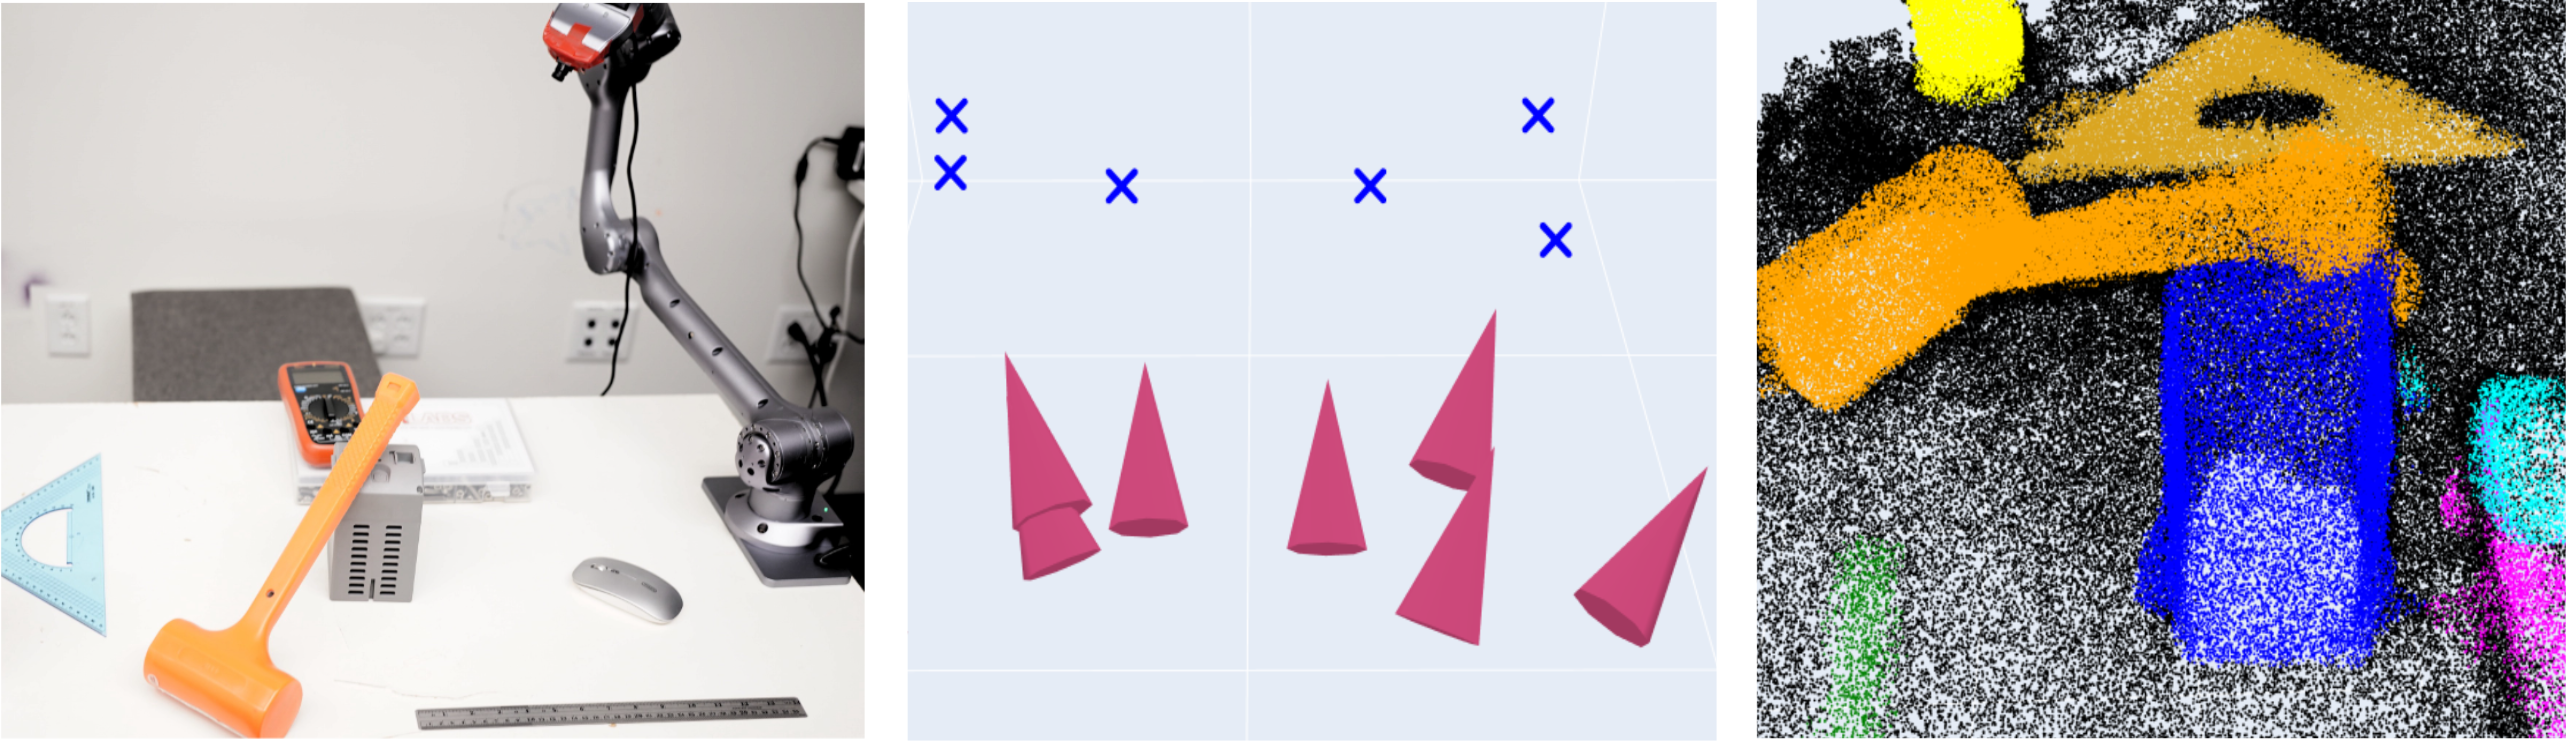
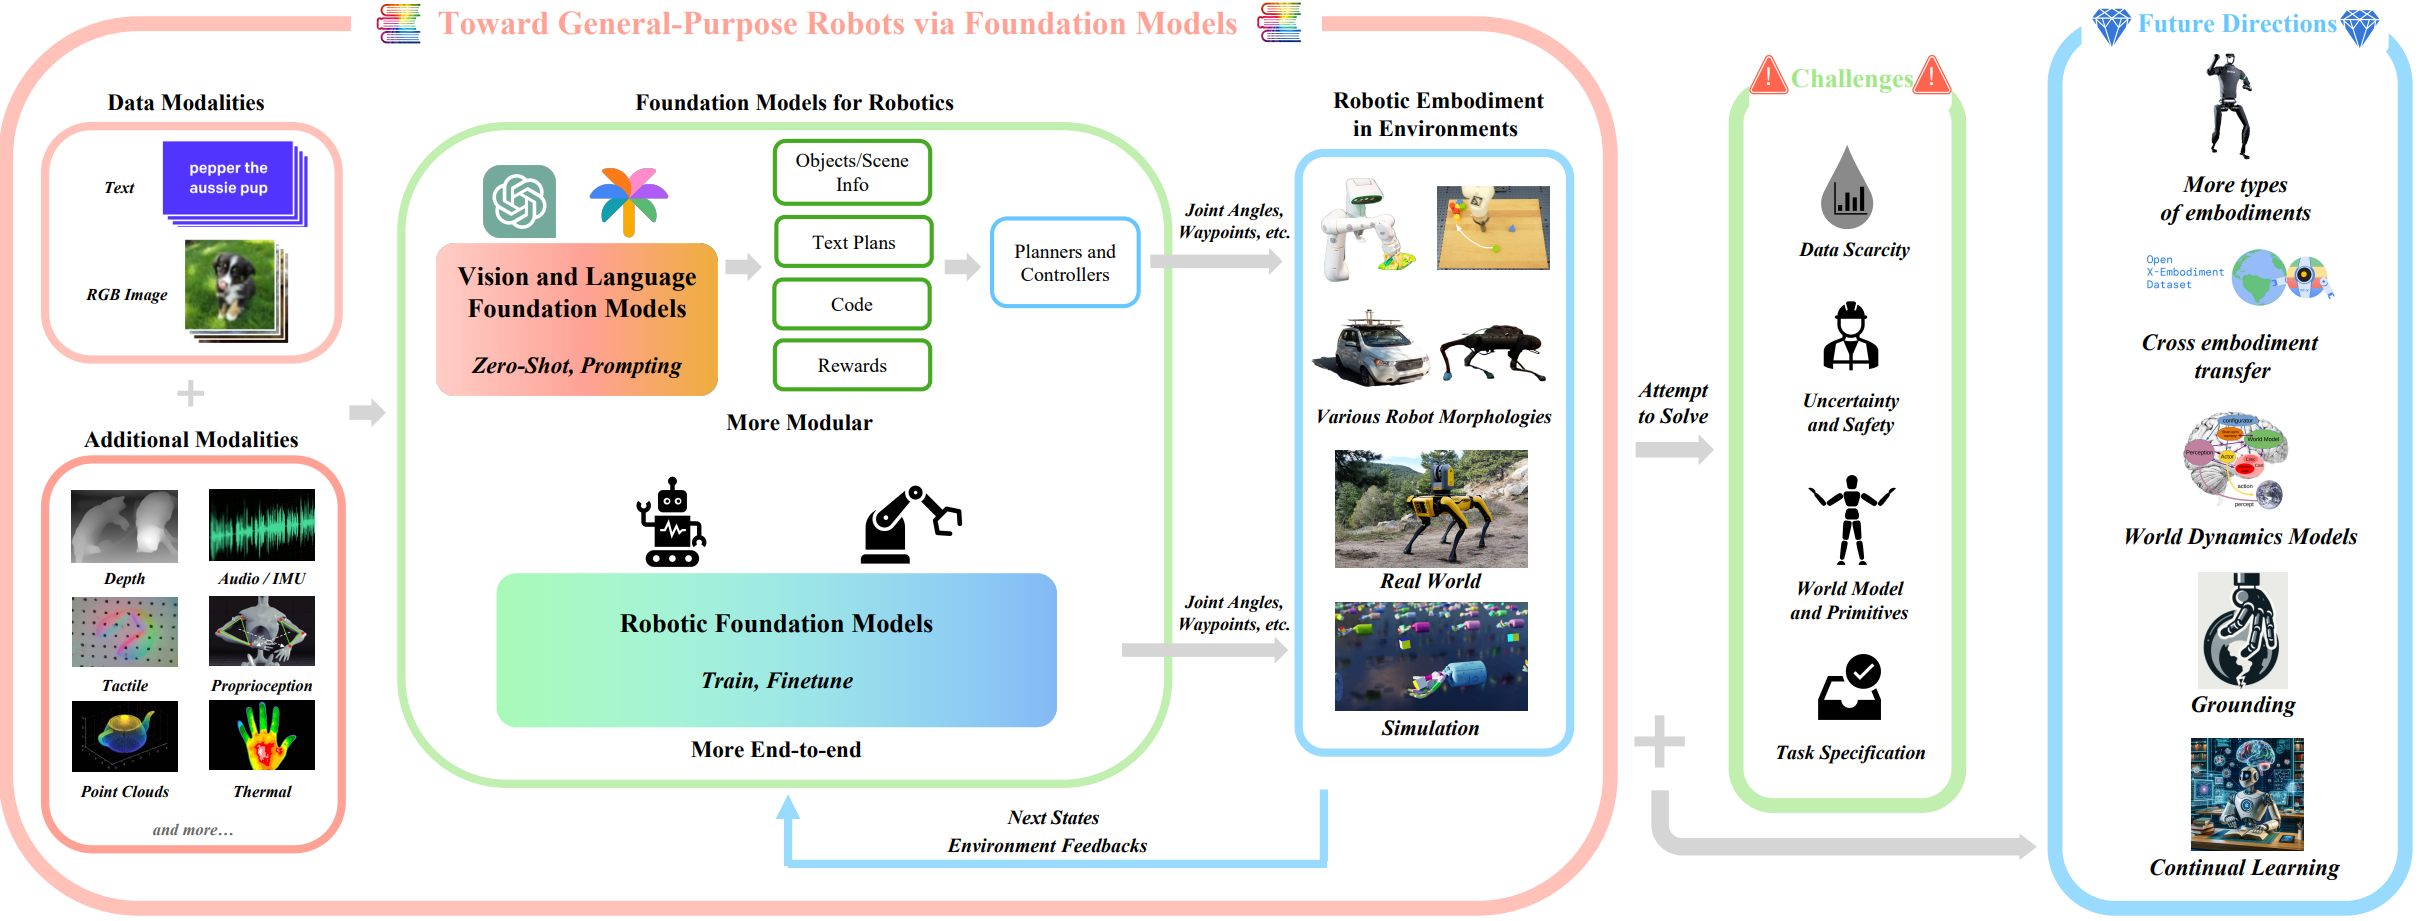
Toward General-Purpose Robots via Foundation Models: A Survey and Meta-Analysis
arxiv | in submission
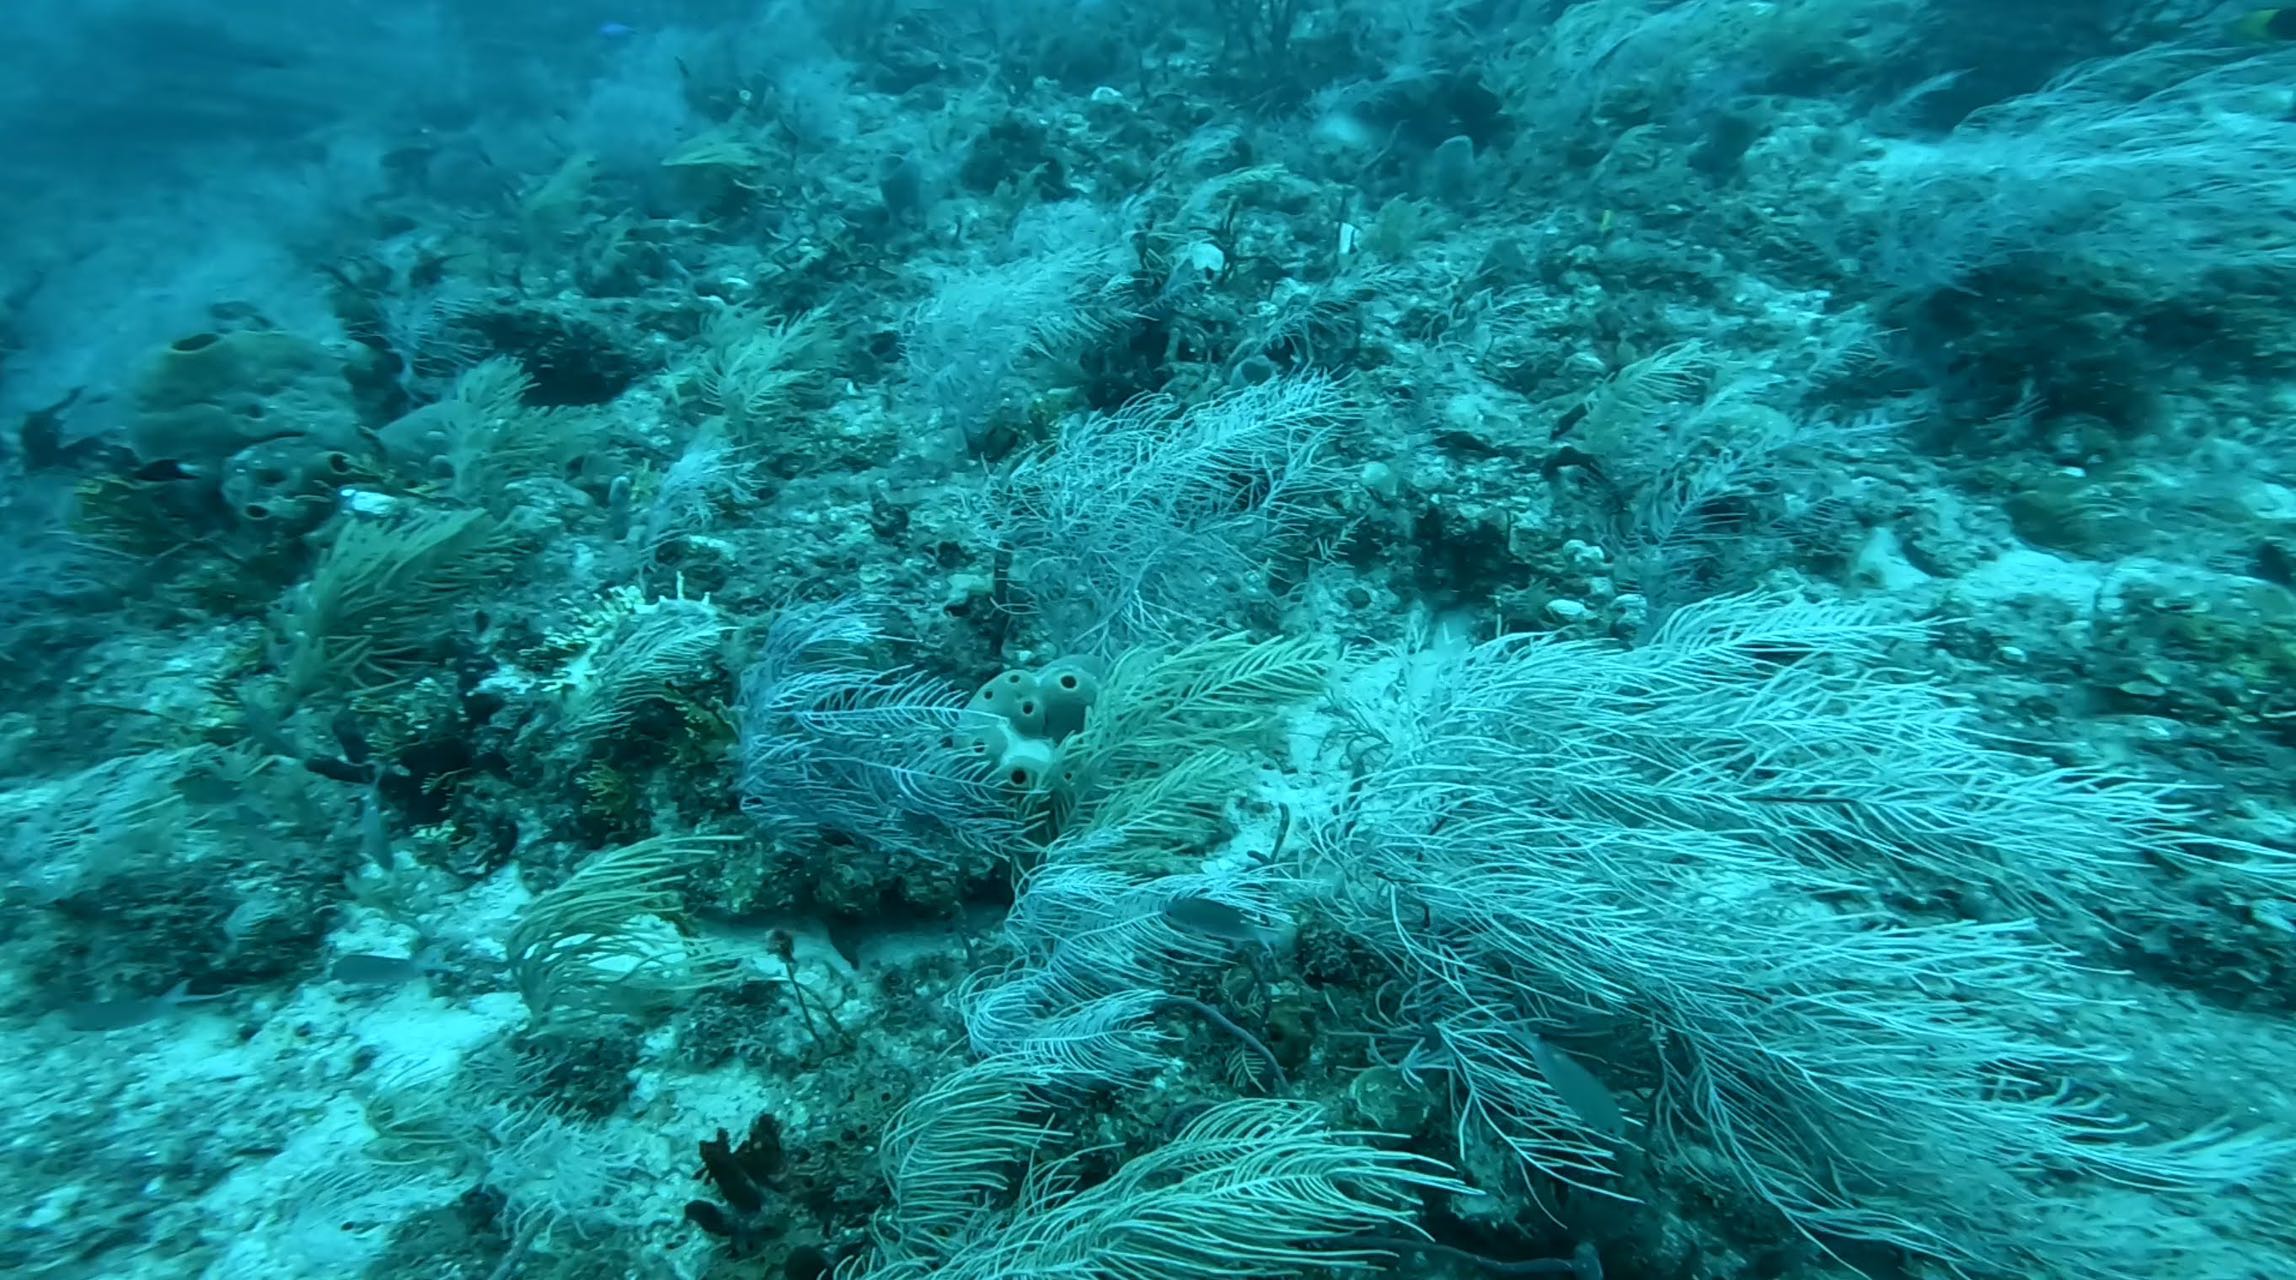
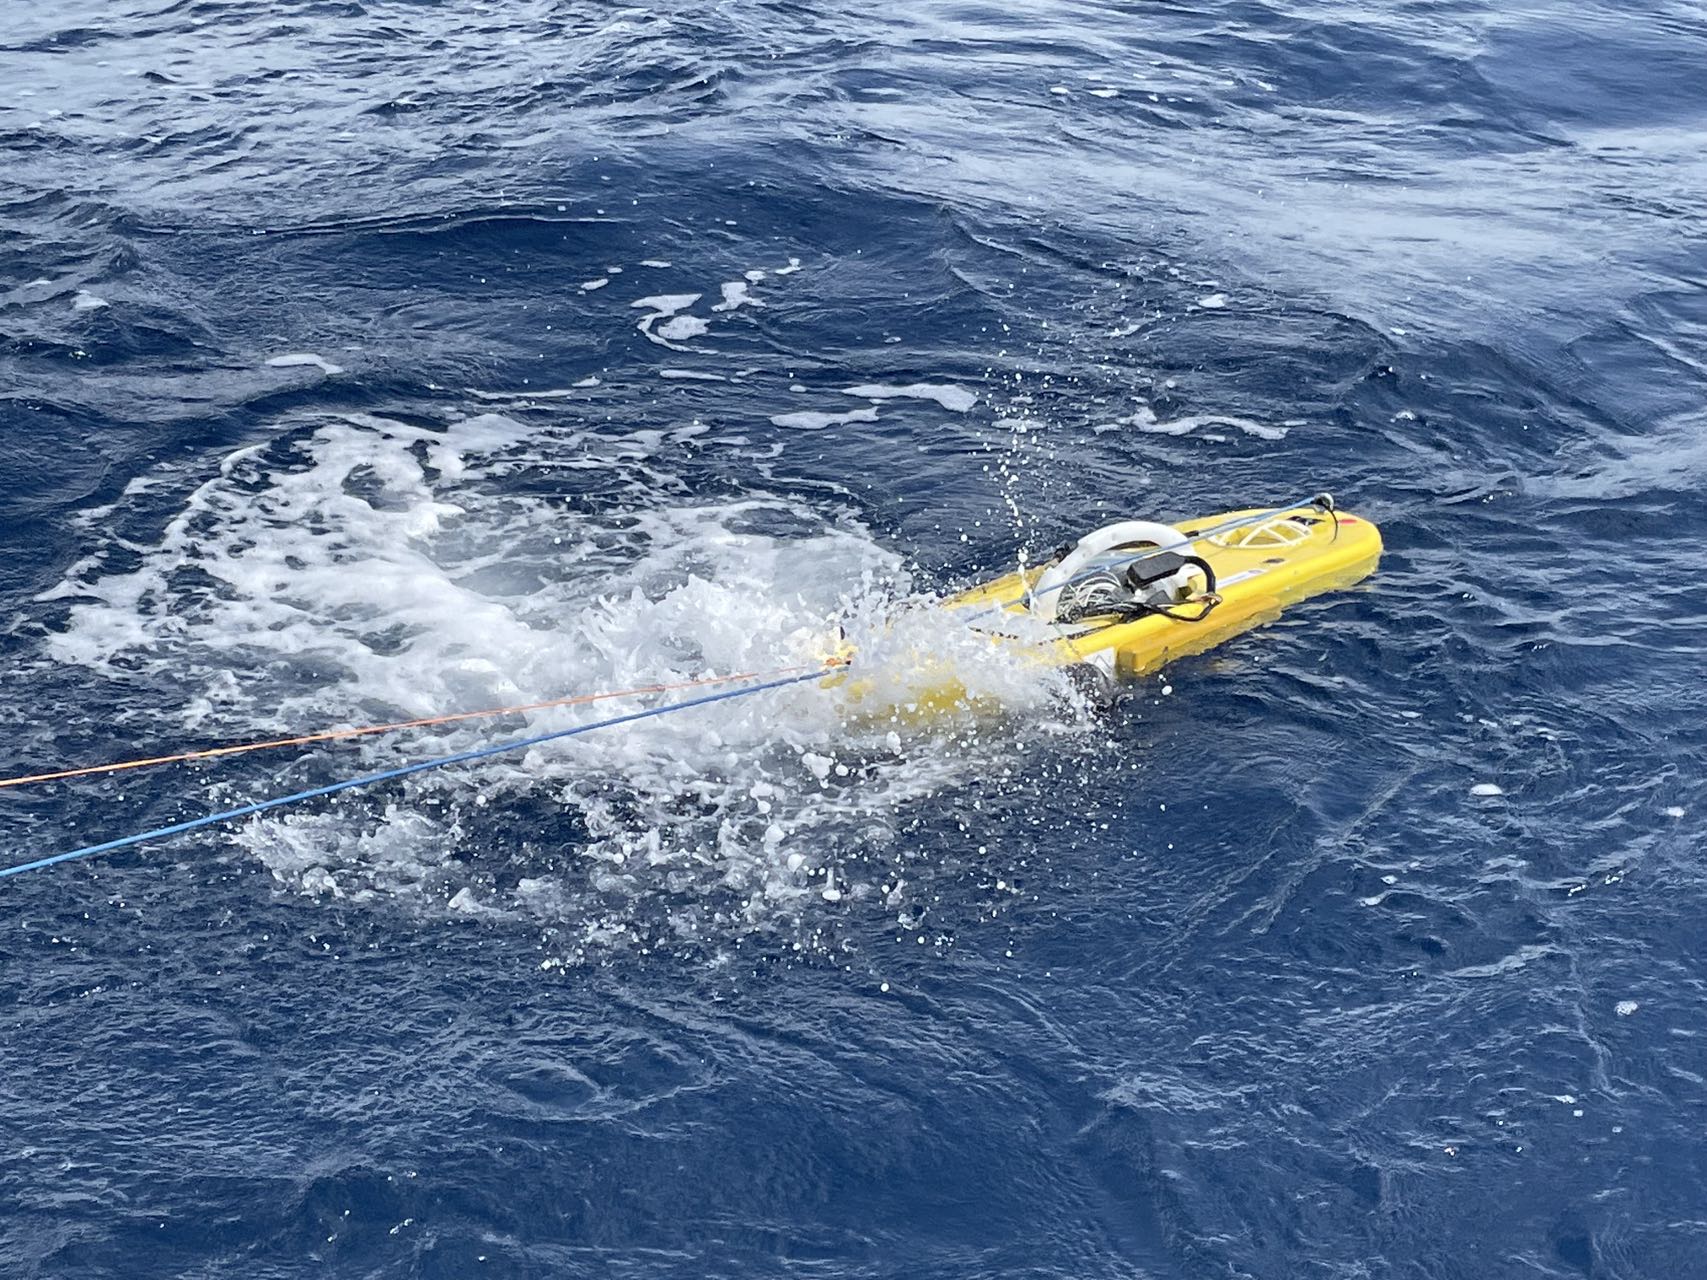
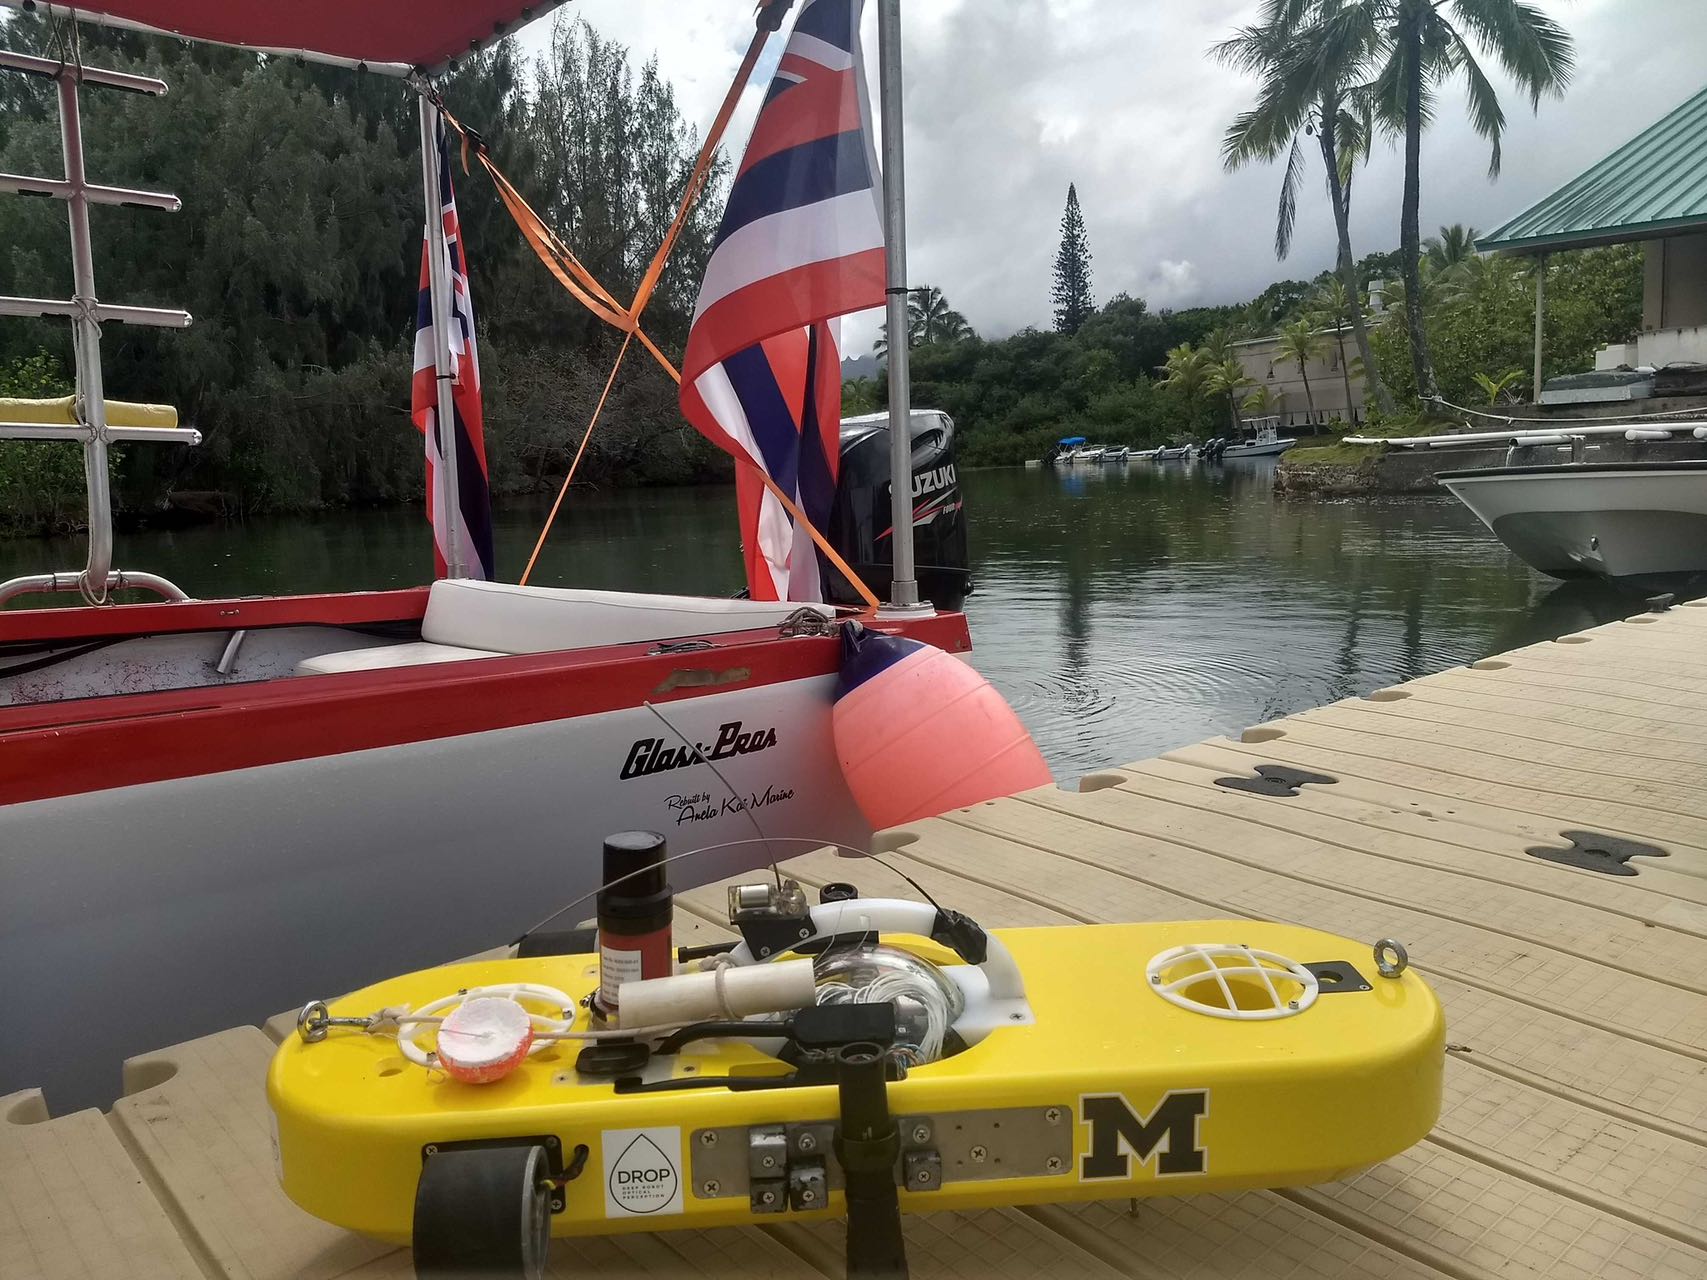
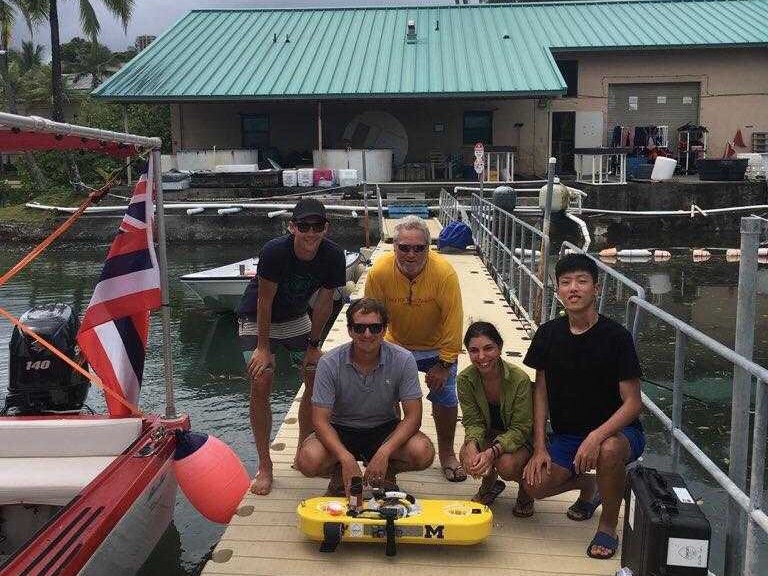
Field Work (Ph.D. research)
Education
-
 Ph.D. Robotics, Carnegie Mellon University (CMU)2022-2025
-
 M.S. Robotics, University of Michigan, Ann Arbor (UM)2018-2020
-
 B.Eng. Tianjin University (TJU)
Work Experience
-
 Software Engineer, Aurora (2025-present)Data-driven sensor simulation.
-
 Software Engineer, Refraction AI (2019)Automated Camera-LiDAR-IMU calibration for a delivery robot.
-
 Visiting Undergrad Researcher, Massachusetts Institute of Technology (2018)
-
 Donut Eater & Software Intern, SLAMTEC (2017 Summer)SLAMTEC builds really good LiDARs and robot platforms. Check it out!
Teaching
-
ROB535 Self-driving Cars: Perception and ControlGraduate Student Instructor · Fall 2021 · UMich
-
16664 Self-driving Cars: Perception and ControlTeaching Assistant · Spring 2023 · CMU
-
16385 Computer VisionTeaching Assistant · Fall 2023 · CMU
Services
Reviewer: T-RO, RA-L, CoRL, ECCV, ICRA, IROS, KDD, NeurIPS, WACV
Thanks Pedro Morgado for this amazing template.